Email Us
News & Insights

Which ROS / ROS2 Distributions Does Our Education & Research Chassis Support?

2026-11-03 0 Leave me a message

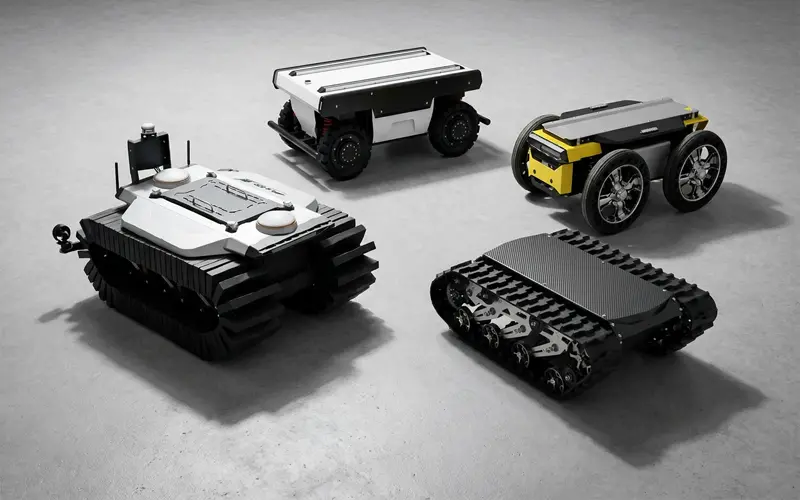
Software compatibility is one of the top concerns for researchers and educators choosing an open robot chassis. Many robot kits simply label themselves “ROS compatible” without clear version support, costing you valuable research time on driver debugging.

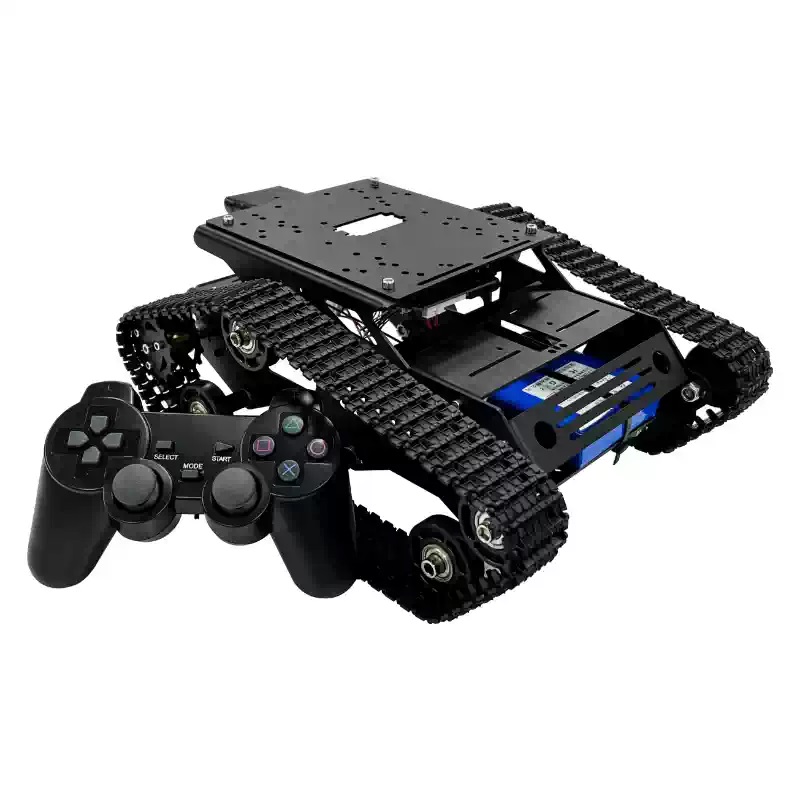
Our secondary-development mobile chassis is officially tested and maintained for these stable releases:

ROS 2 Humble Hawksbill (Ubuntu 22.04, LTS)

Our primary recommended version. It works seamlessly with Nav2, Cartographer SLAM, Gazebo simulation, Raspberry Pi and Jetson. Ideal for university courses and student research projects.

ROS 2 Jazzy Jalisco (Ubuntu 24.04, LTS)

Newer long-term support release for labs running Ubuntu 24.04 and long-cycle research. All drivers, URDF models and launch files are fully ported and verified.

ROS Noetic Ninjemys (ROS 1, Ubuntu 20.04)

Legacy support only. For teams maintaining old ROS1 code and existing lab projects. New projects should use ROS2.

ROS 2 Rolling Ridley

Community-supported branch for advanced developers testing cutting-edge ROS features. Not recommended for teaching or stable experiments.

When we say a distribution is supported, you get ready-to-run ROS packages, URDF models, launch files and matched setup guides. You have access to odometry, velocity control and low-level interfaces for secondary development.

✅ Teaching & student projects → ROS2 Humble

✅ New long-term research → ROS2 Jazzy

✅ Legacy ROS1 experiments → ROS Noetic

Same hardware can switch between Humble and Jazzy. No mechanical changes required.Reach out to our team if you need the matching software package for your ROS environment. 

Check our product page for full chassis specs and quotation.

Related News
Leave me a message
Email
info@tjwdhk.cn
Address
Room 3025, Building 1, Zone F, Guangxuan Road, Airport International Headquarters Base, Dongli District, Tianjin City, China
X
We use cookies to offer you a better browsing experience, analyze site traffic and personalize content. By using this site, you agree to our use of cookies. Privacy Policy
RejectAccept